Bullseye grading agreement, well above the 75% target
Measurement error against a 0.50-inch threshold
Real-time processing latency, with one model scaling across multiple packaging lines
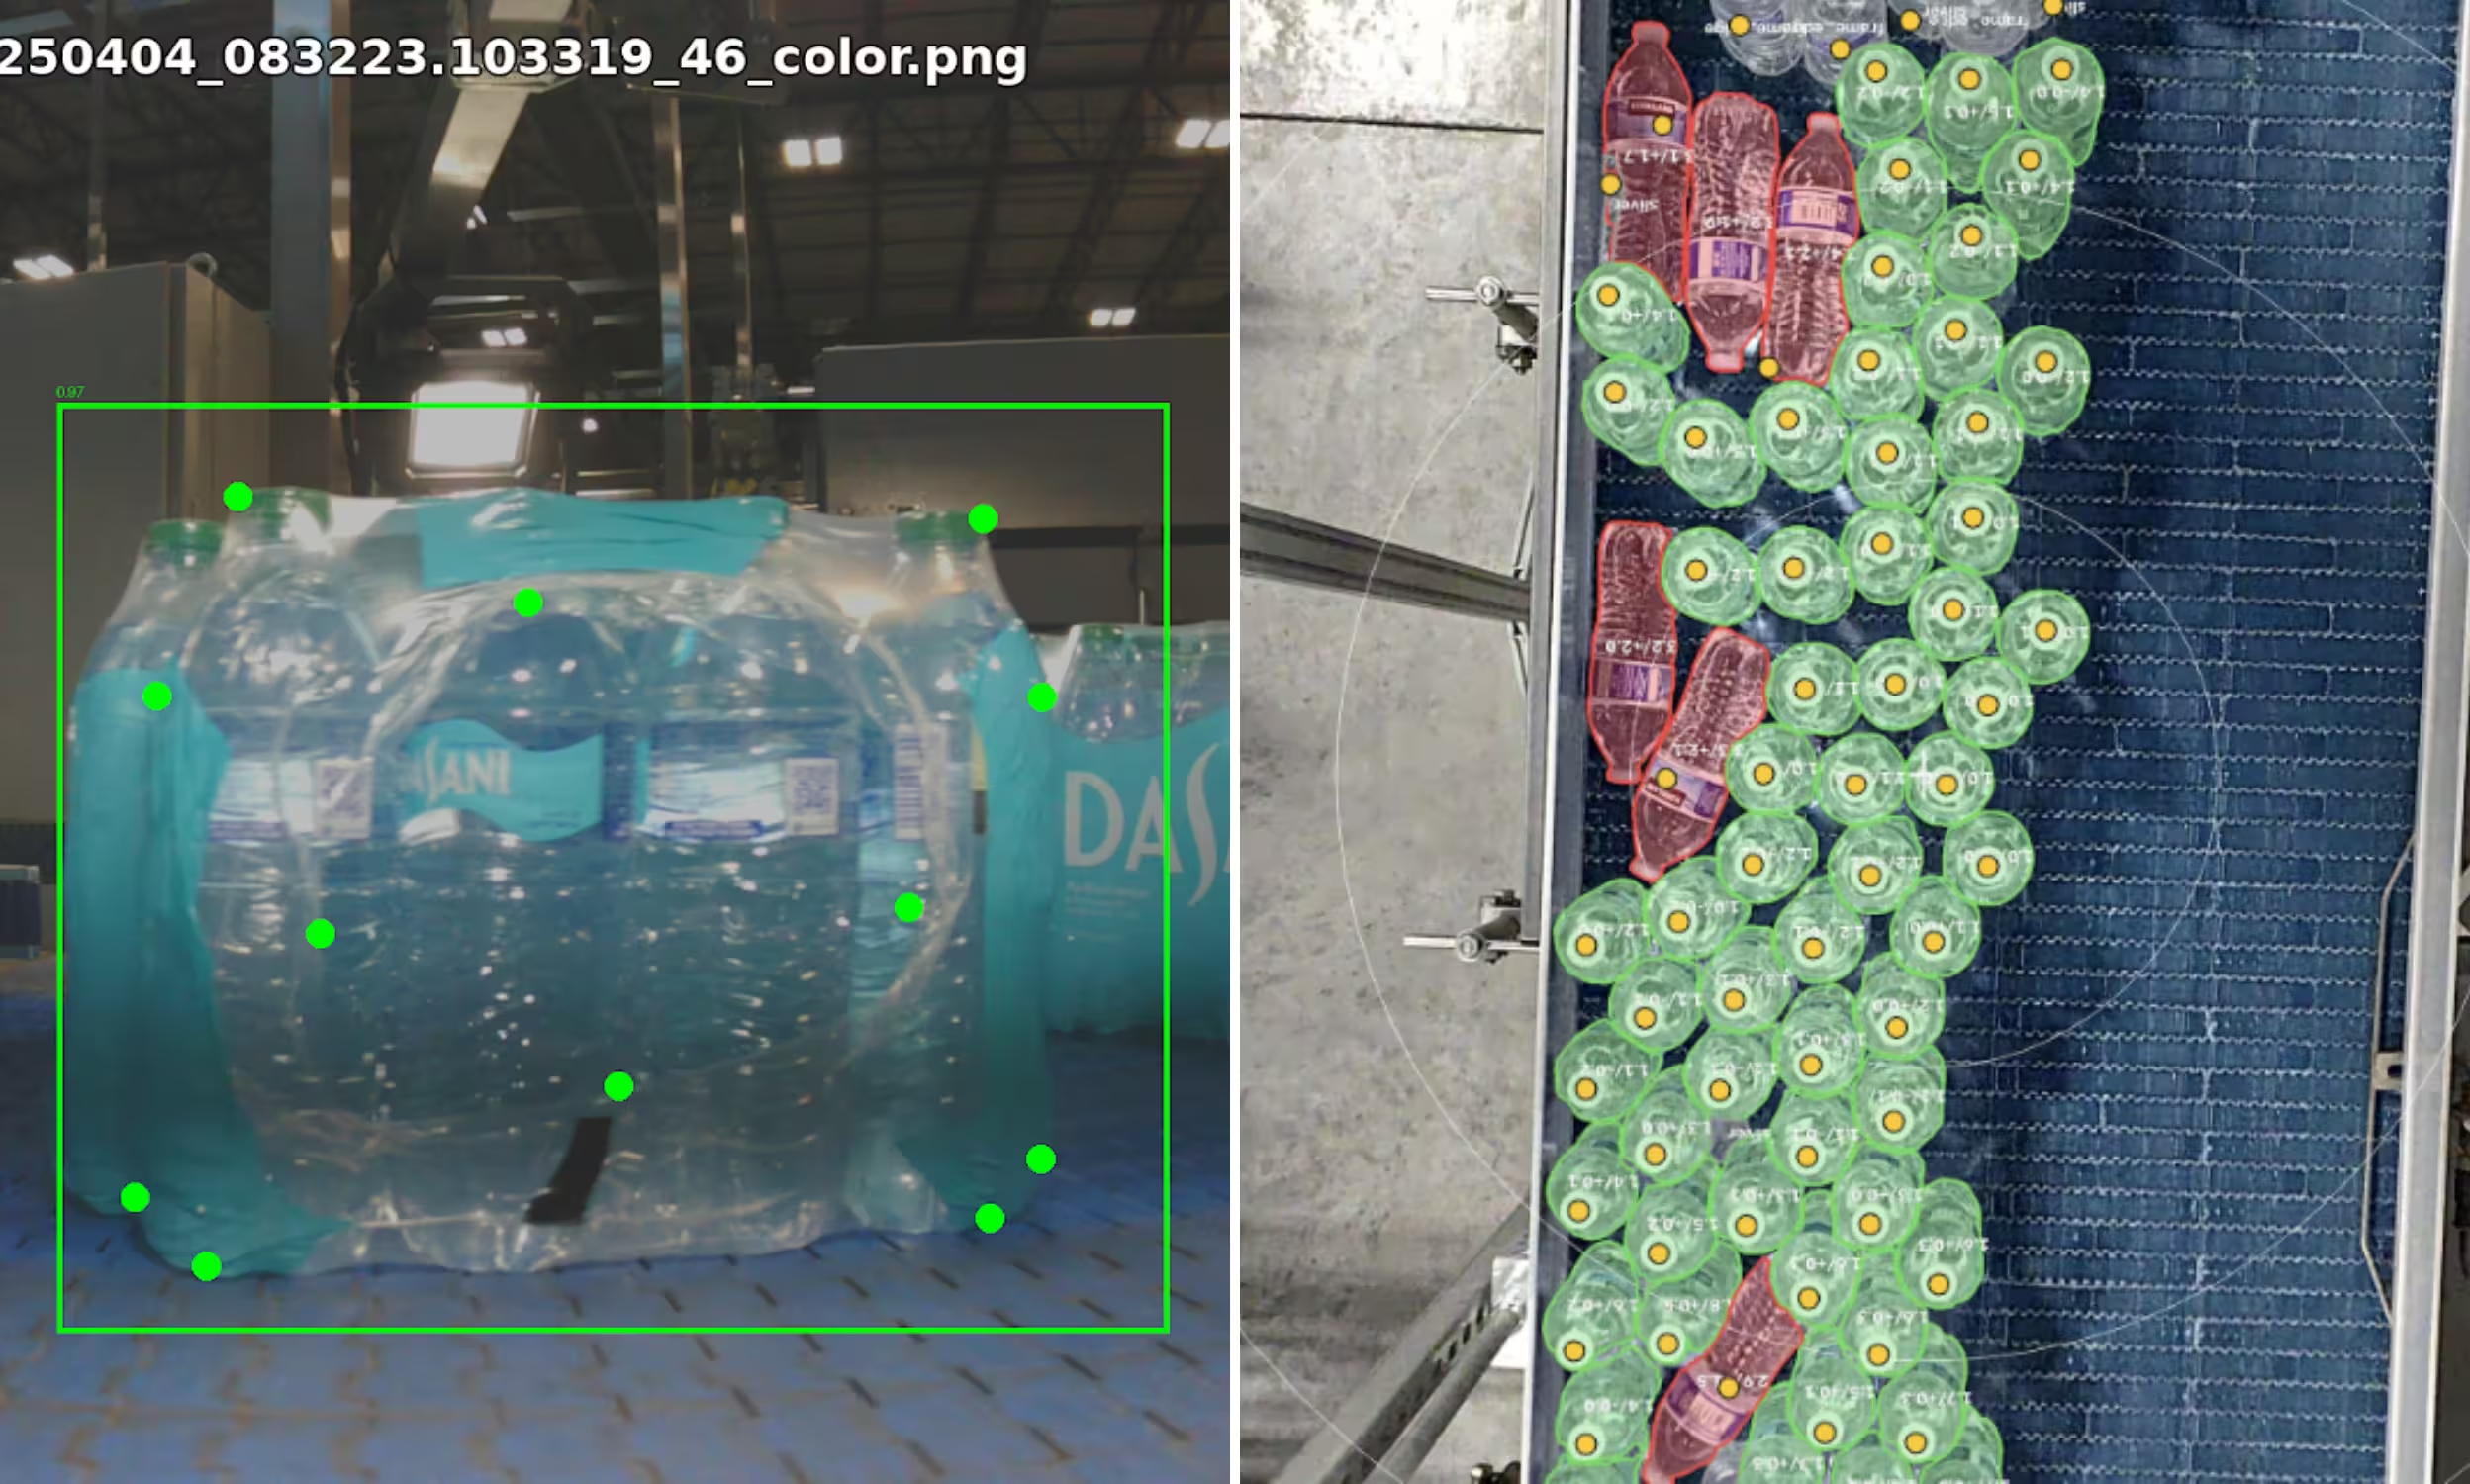
A leading beverage bottler required an automated, real-time quality control solution for shrink-wrapped bottle packages, emphasizing bullseye handles and film creases critical to package strength. The existing proprietary camera systems demanded per-line calibration, frequently missed defects, and created quality inconsistencies that disrupted operations.
The manufacturer sought a faster, more precise, and scalable inspection method across production lines that would minimize human judgment and reduce per-plant deployment expenses.
Fallen bottles on the conveyor created a second problem. Line teams knew bottles went down but had no record of where along the line it happened or how often, which made it guesswork to know which section to fix.
OneSix designed and built an edge-based, AI-driven computer vision system that detects bullseye defects and packaging creases using a single multi-task model. The system converts pixel data into real-world measurements and applies automated PASS / WARN / FAIL grading, removing operator subjectivity from the inspection process.
The solution runs on affordable edge devices (Jetson Orin NX), supporting four to five cameras per line with minimal hardware and 50ms processing latency. A single trained model scales across multiple packaging lines with minimal per-line tuning, lowering deployment cost and accelerating rollout across plants.
SCADA and Azure integration enables real-time floor monitoring and historical data retention for ongoing optimization. Production results achieved 95% bullseye grading accuracy surpassing the 75% benchmark and measurement precision between 0.05-0.19 inches compared to the 0.50-inch threshold.
Building on the same edge architecture, OneSix built a system to find and map fallen bottles across the line. Eight cameras each run a detection model on-device, decoding 4K video at 30 frames per second and inferring in real time without sending footage off the floor.
Camera views do not overlap, so the system deduplicates events across all eight to give one accurate count instead of eight partial ones. Charuco calibration boards fix each camera's pose, and because conveyors are flat, that pose plus the camera's factory calibration is enough to place every detection at a real position on the line.
The model classifies three things: upright bottles, down bottles, and caps. Reading the cap gives the orientation of a fallen bottle, so the team can tell which way bottles are going over.
Labeling is largely automated. Segmentation masks flag frames where a detected shape appears somewhere an upright bottle could not be, and a lightweight tracker follows each suspected event across camera angles to confirm it before it becomes training data. Low-confidence regions are excluded from supervision rather than guessed at.
Results land in a web app with heatmaps showing where along the line bottles fall, plus video of each event for review. Line teams can see which section is the problem rather than inferring it from downstream counts.
More to explore
By consolidating data into a cloud-based data warehouse, OneSix empowered a 3PL provider to achieve real-time, accurate reporting, streamline inventory planning, and enhance operational efficiency.
OneSix partnered with a healthcare data company to build a secure, scalable data platform using Snowflake, Python, and Sigma—enabling centralized data management, automated reporting, and robust governance.
OneSix built a governed data marketplace and multi-year maturity program that turns the company's data into productized, monetizable assets.